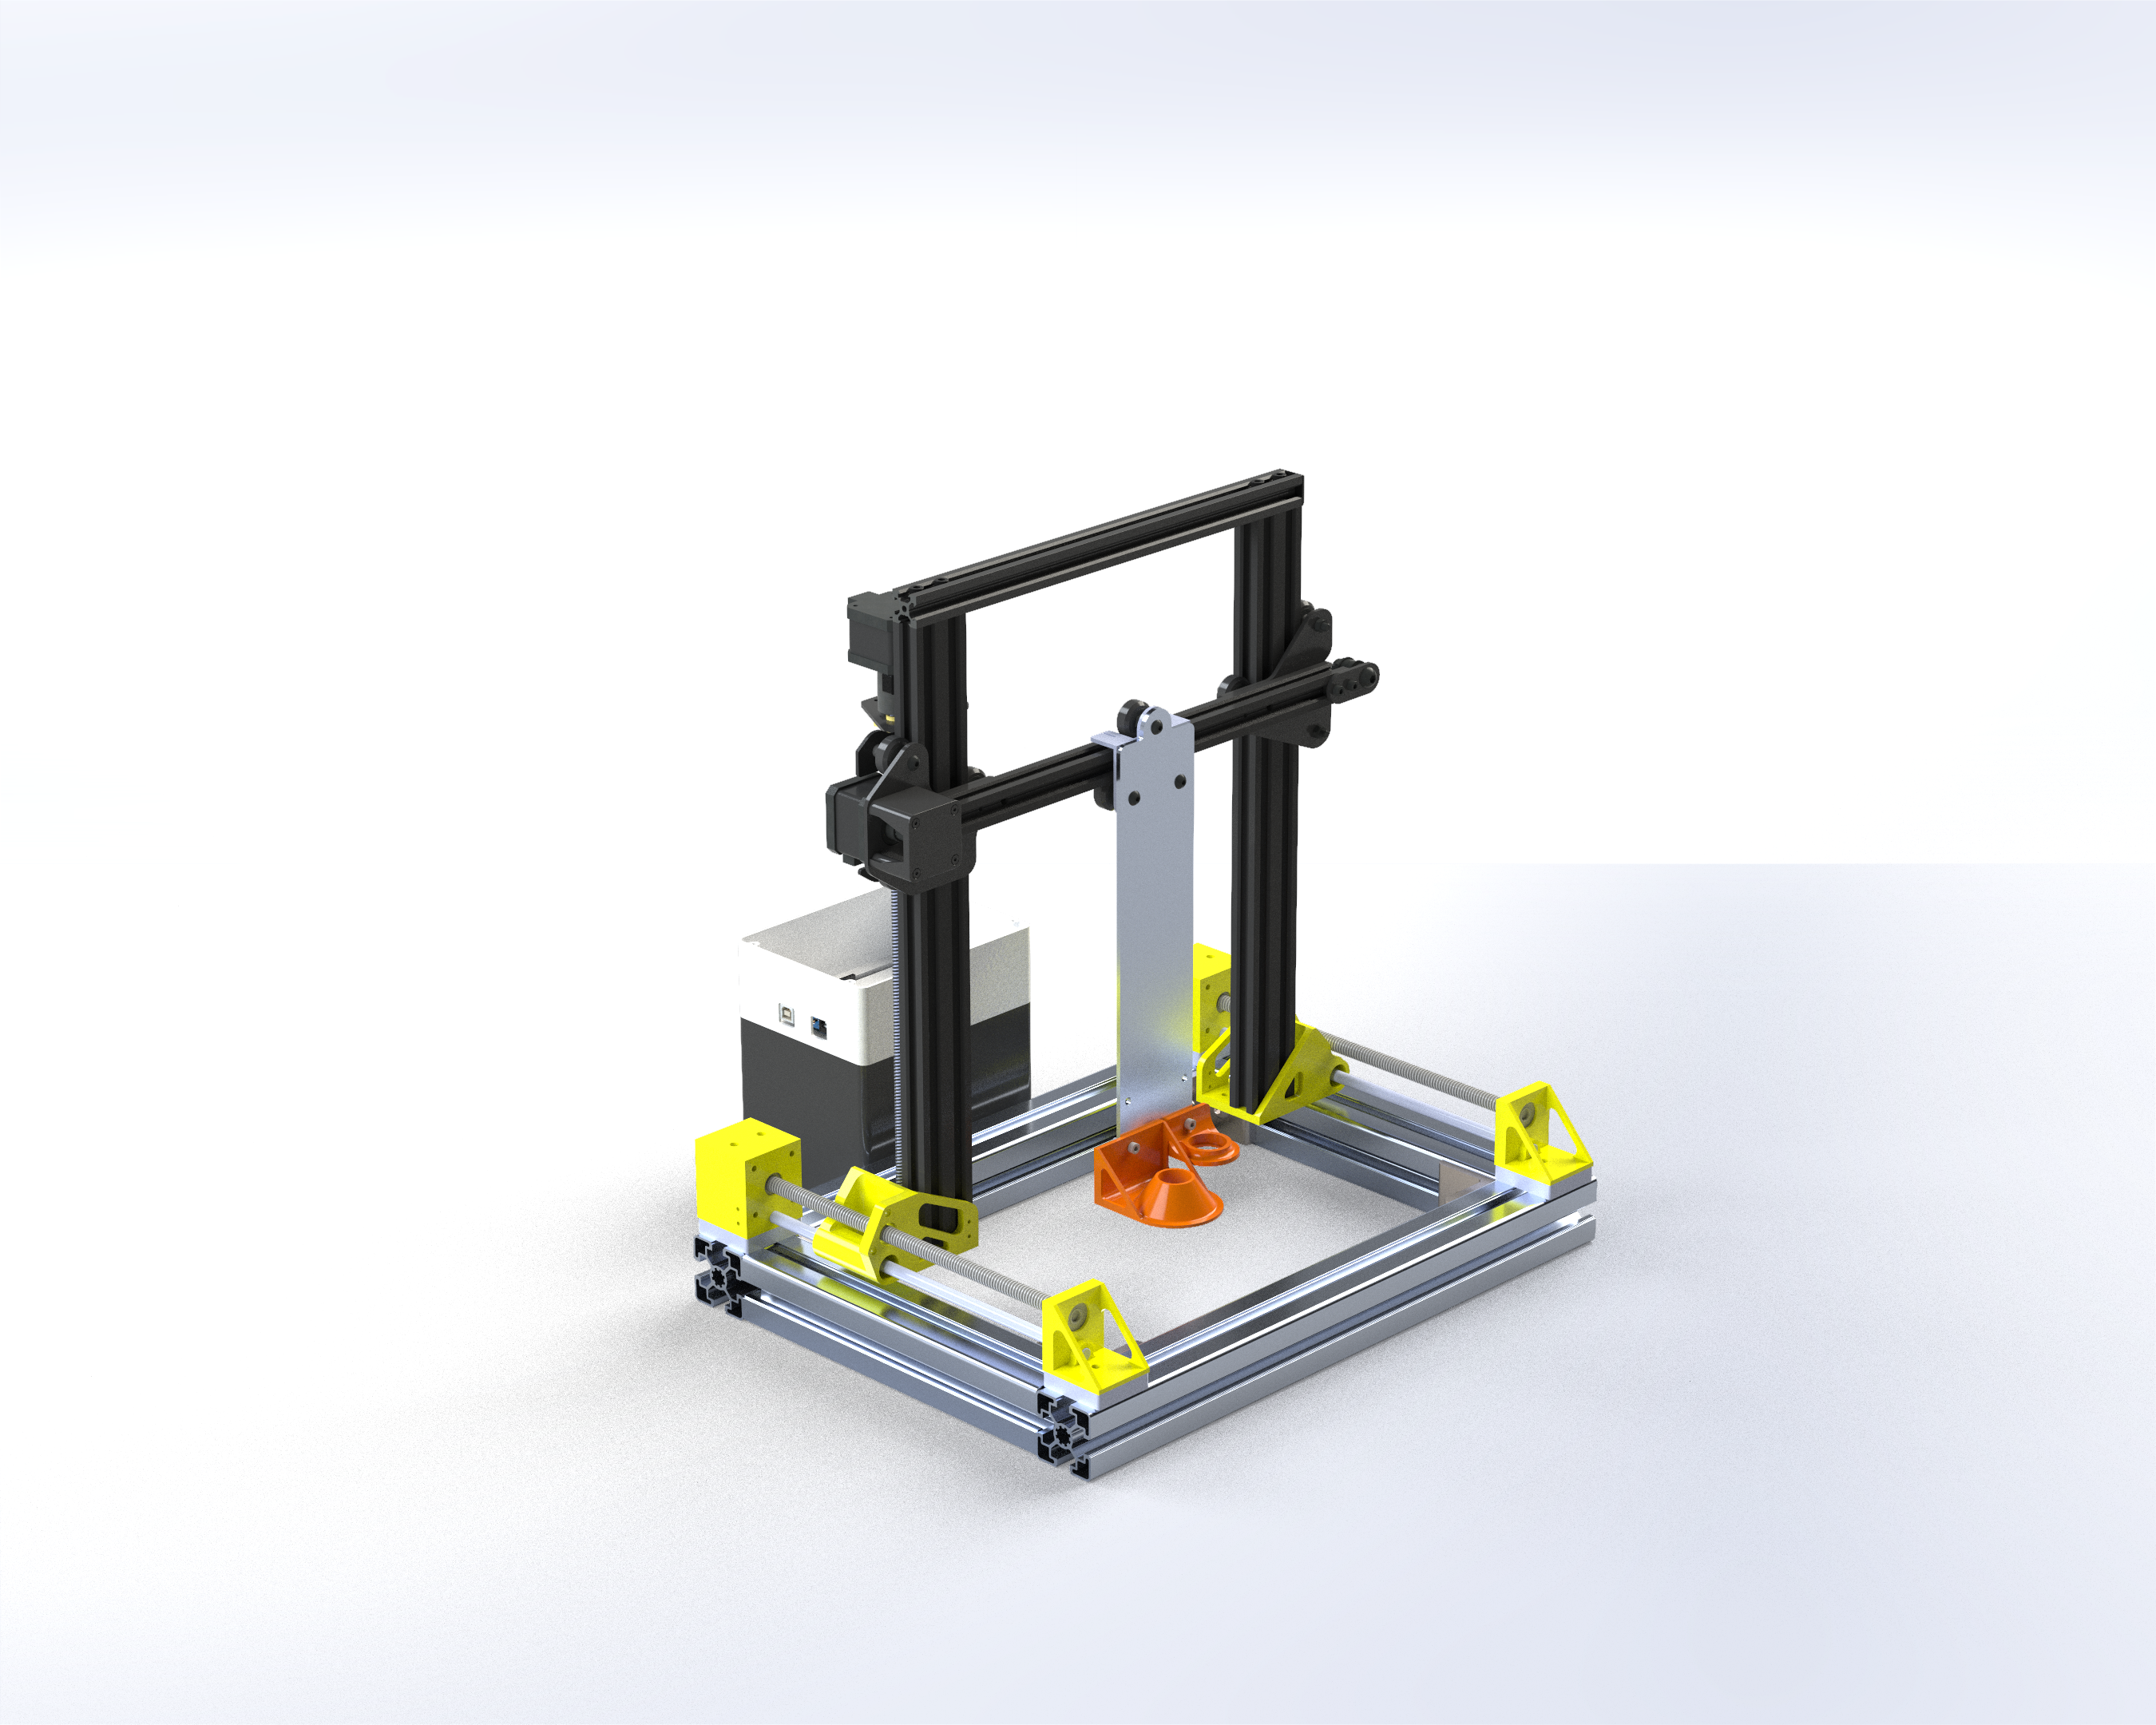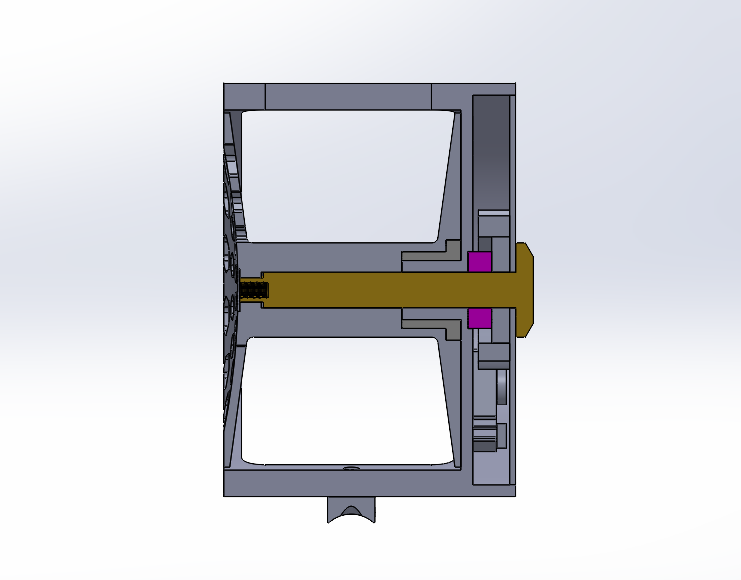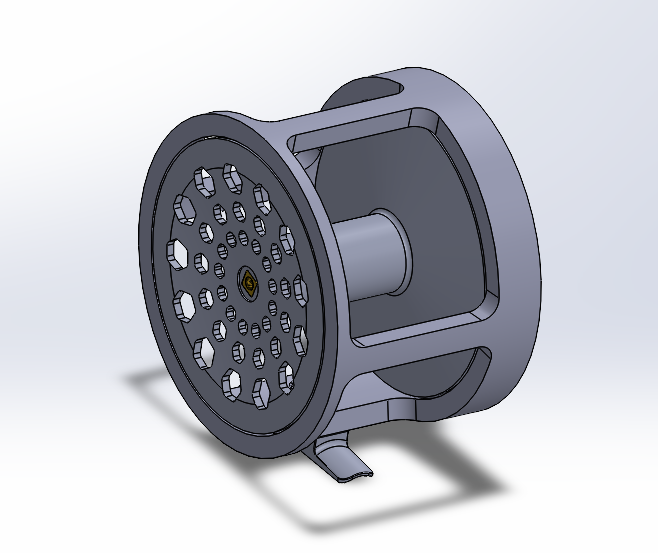
Engineered an automated acoustic scanning framework designed for high-resolution non-destructive evaluation (NDE) of submerged targets using water coupling and multi-axis automated positioning.
Mechanical Design & Structural FEA
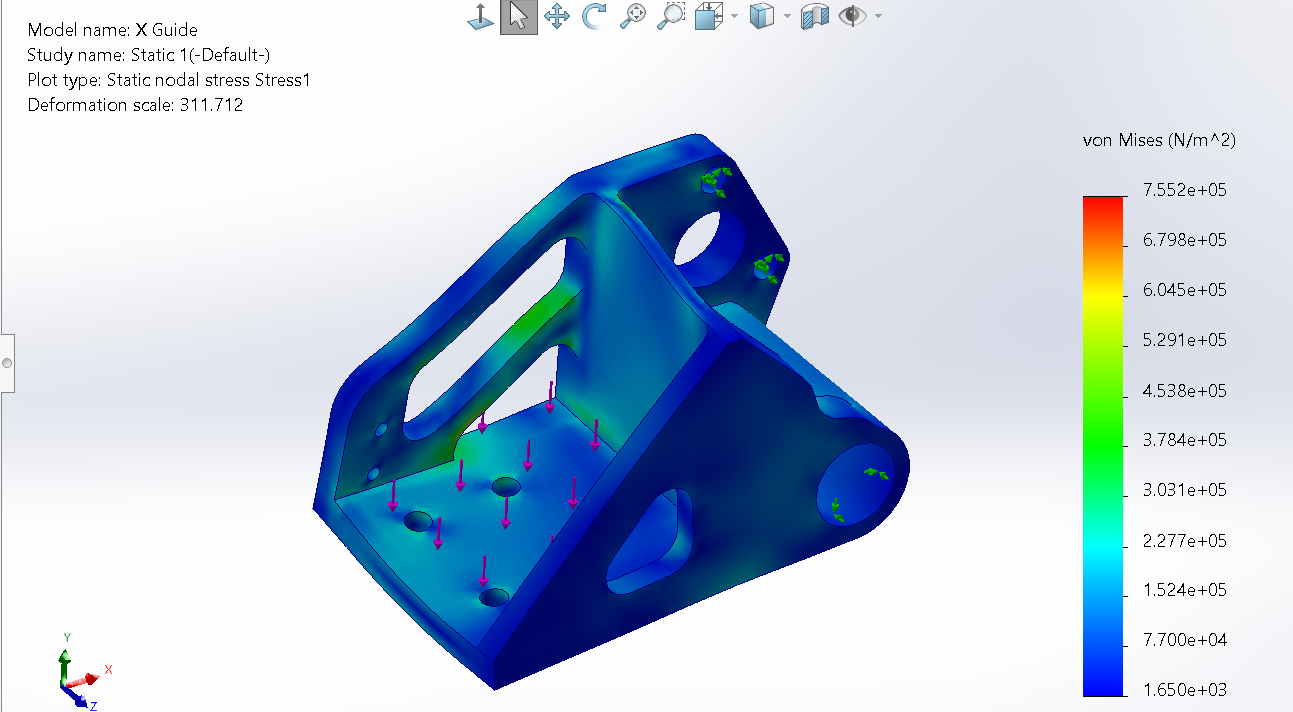
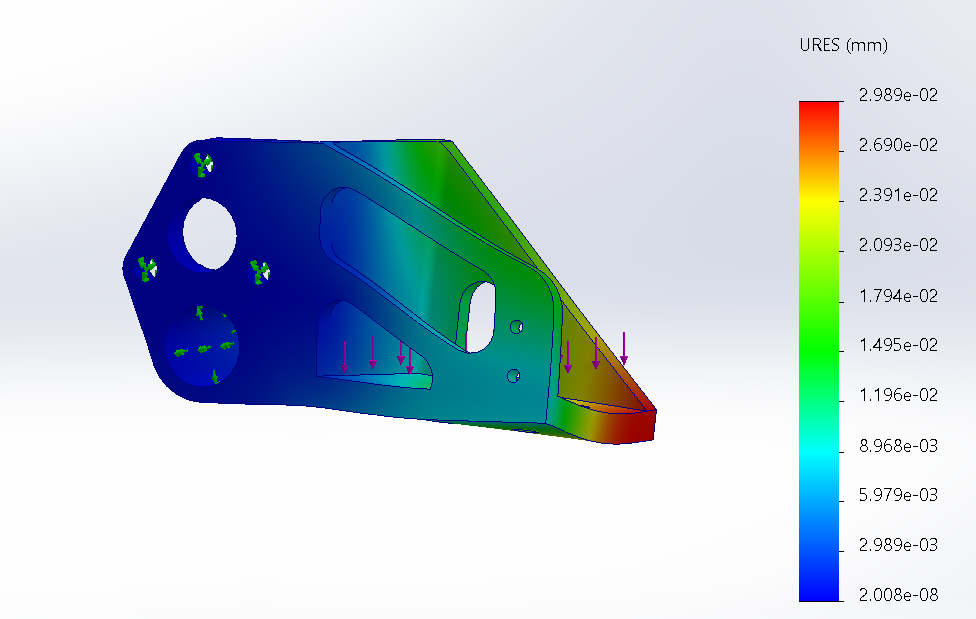
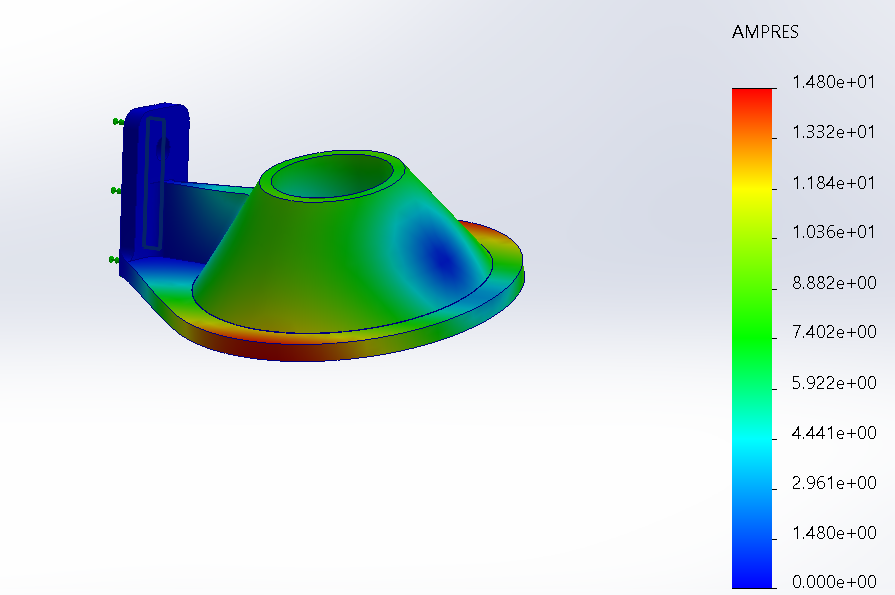
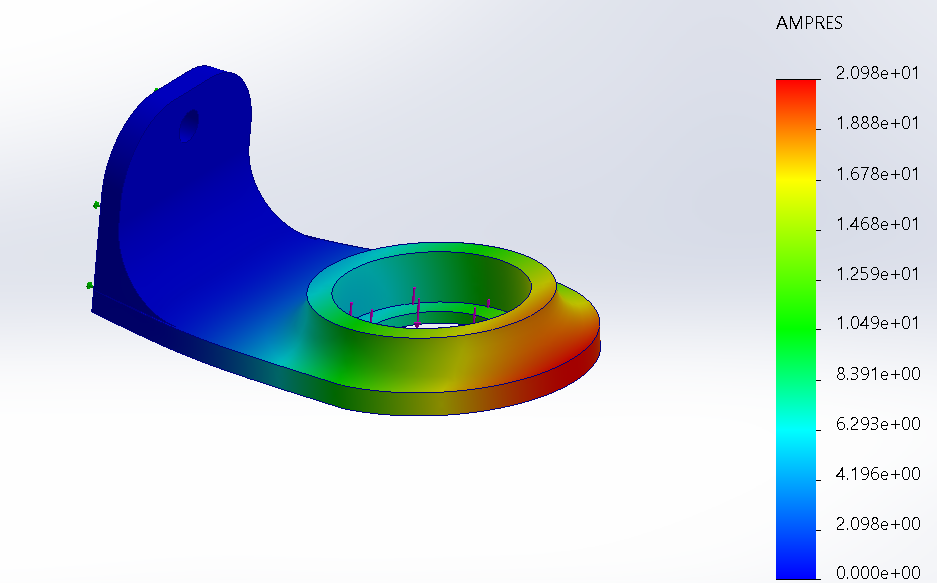
Designed a custom multi-axis gantry system built for precise, repeatable movements over a fluid coupling tank. Conducted FEA Von Mises stress and static displacement simulations to ensure zero deflection during motion. Performed modal frequency analysis to guarantee structural natural frequencies don't induce acoustic resonance.
Motion Control & Automation
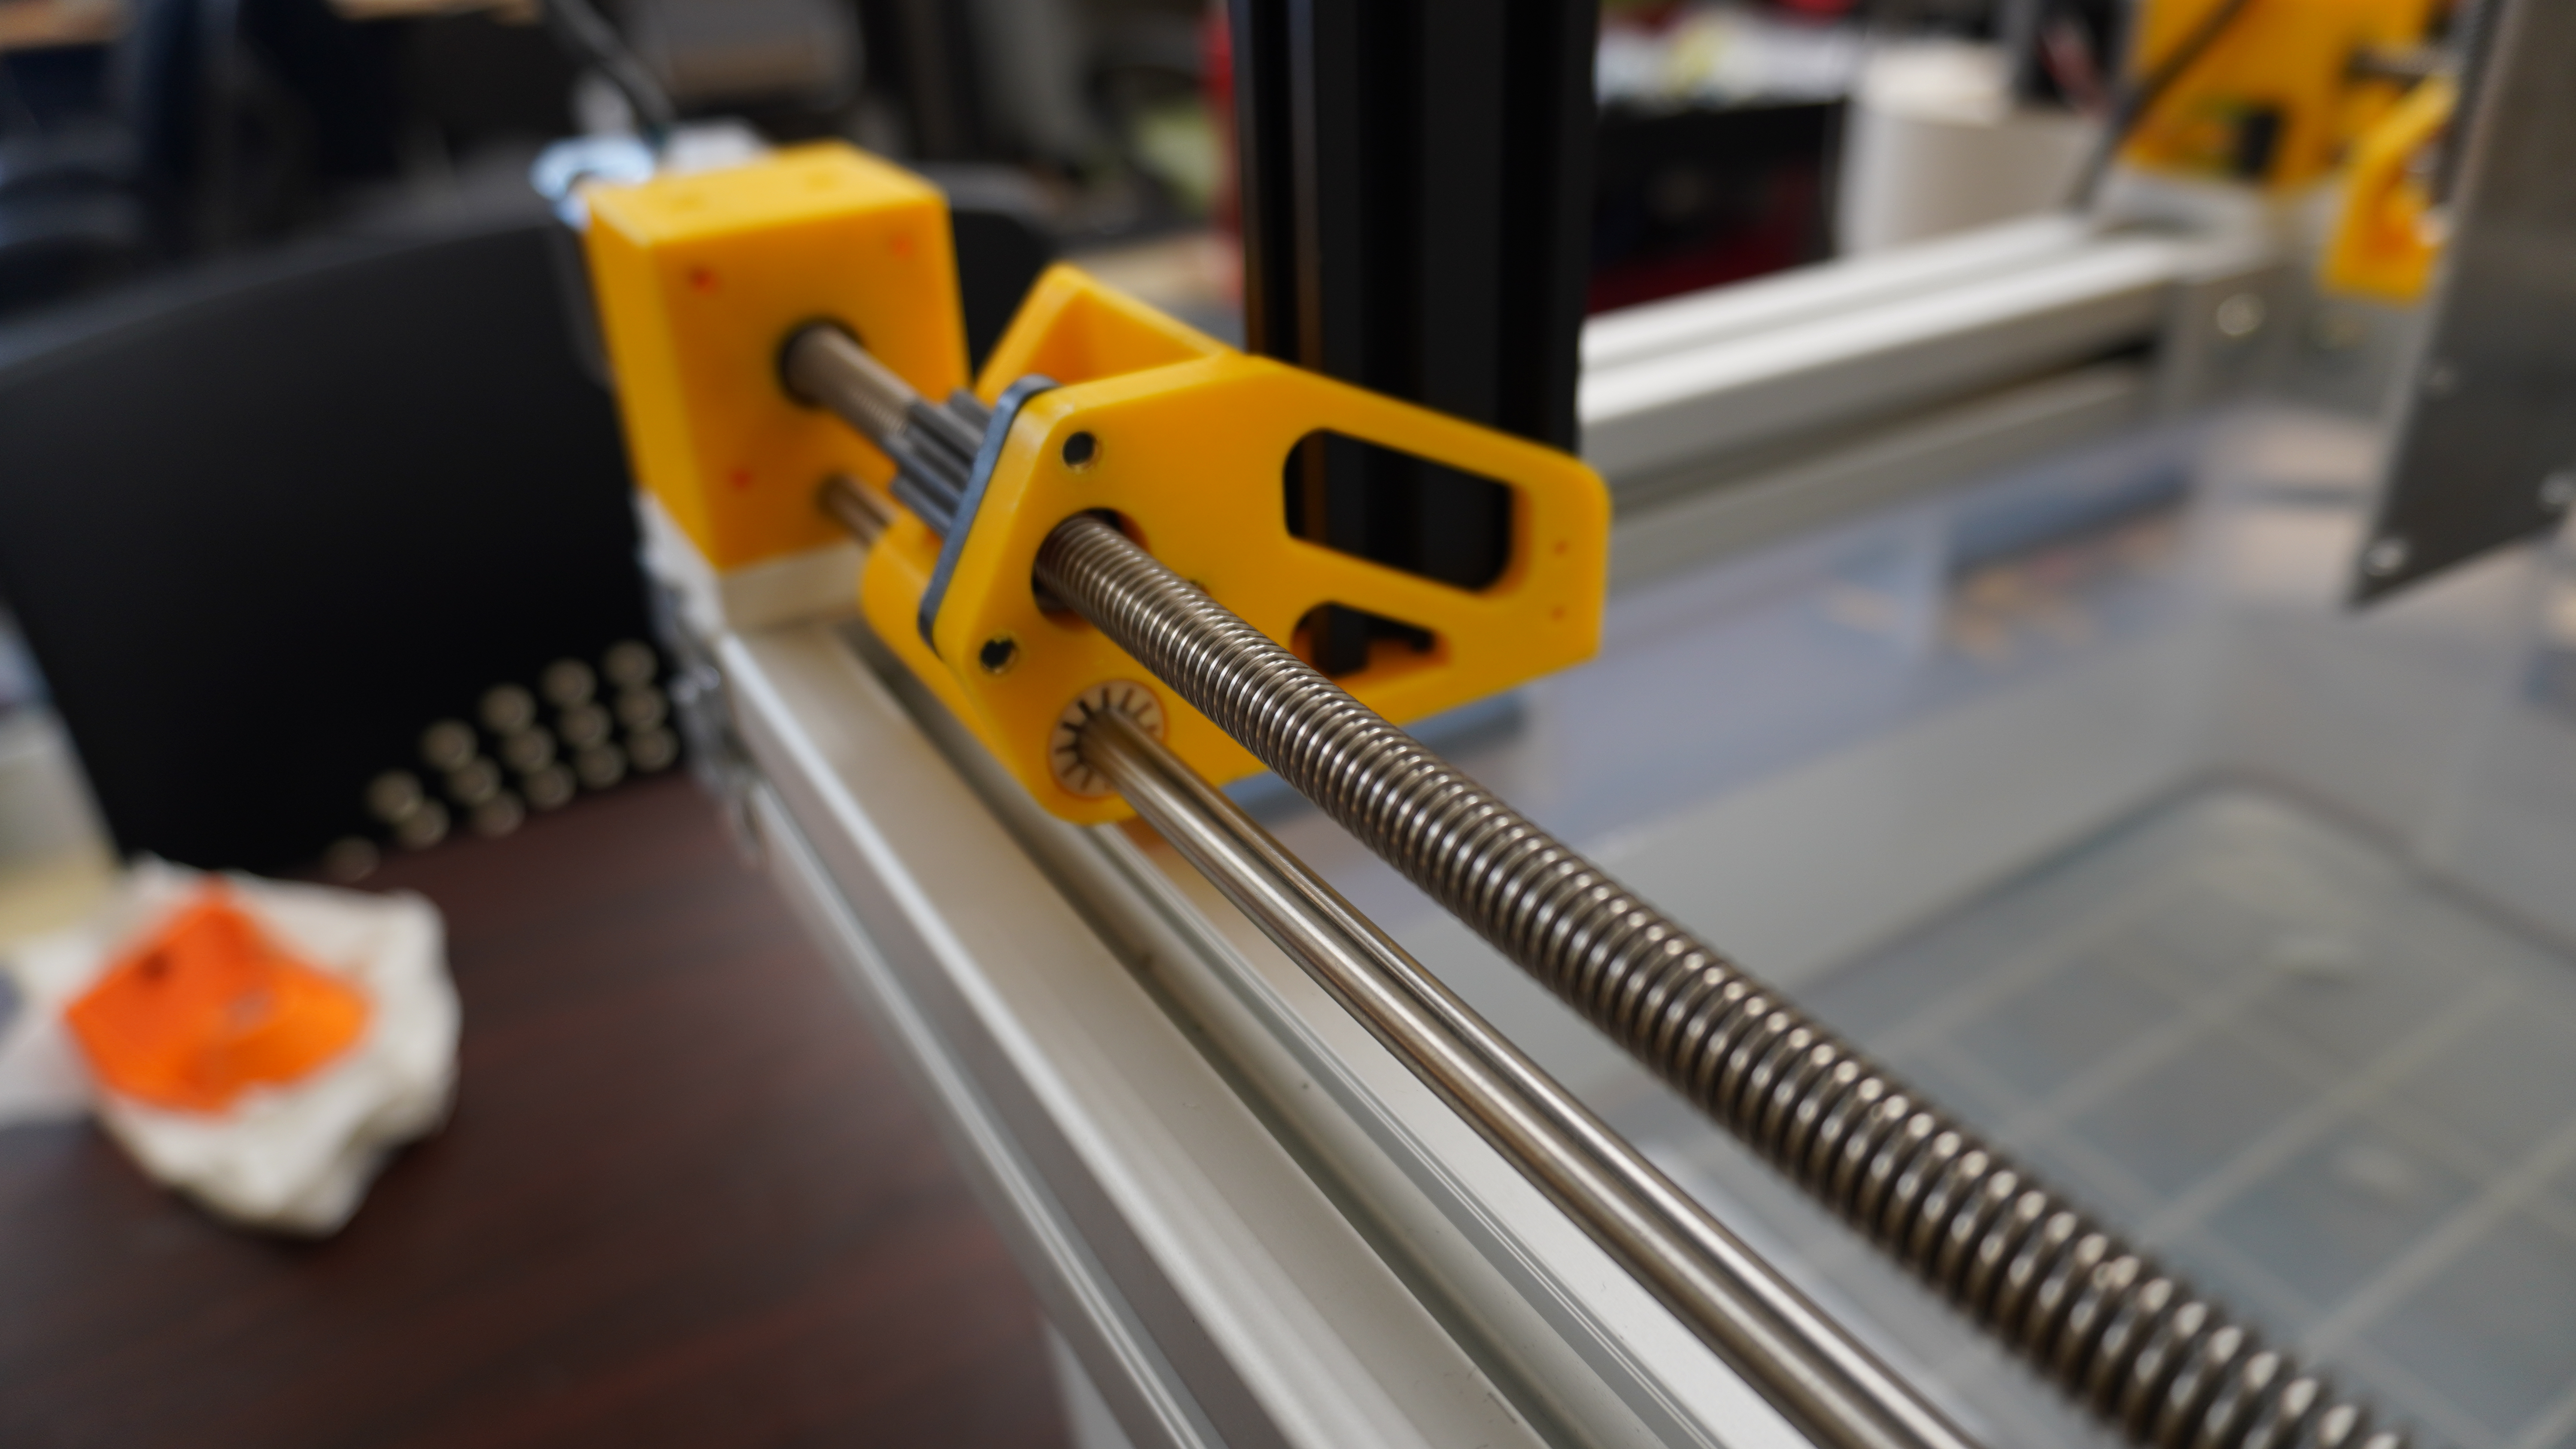
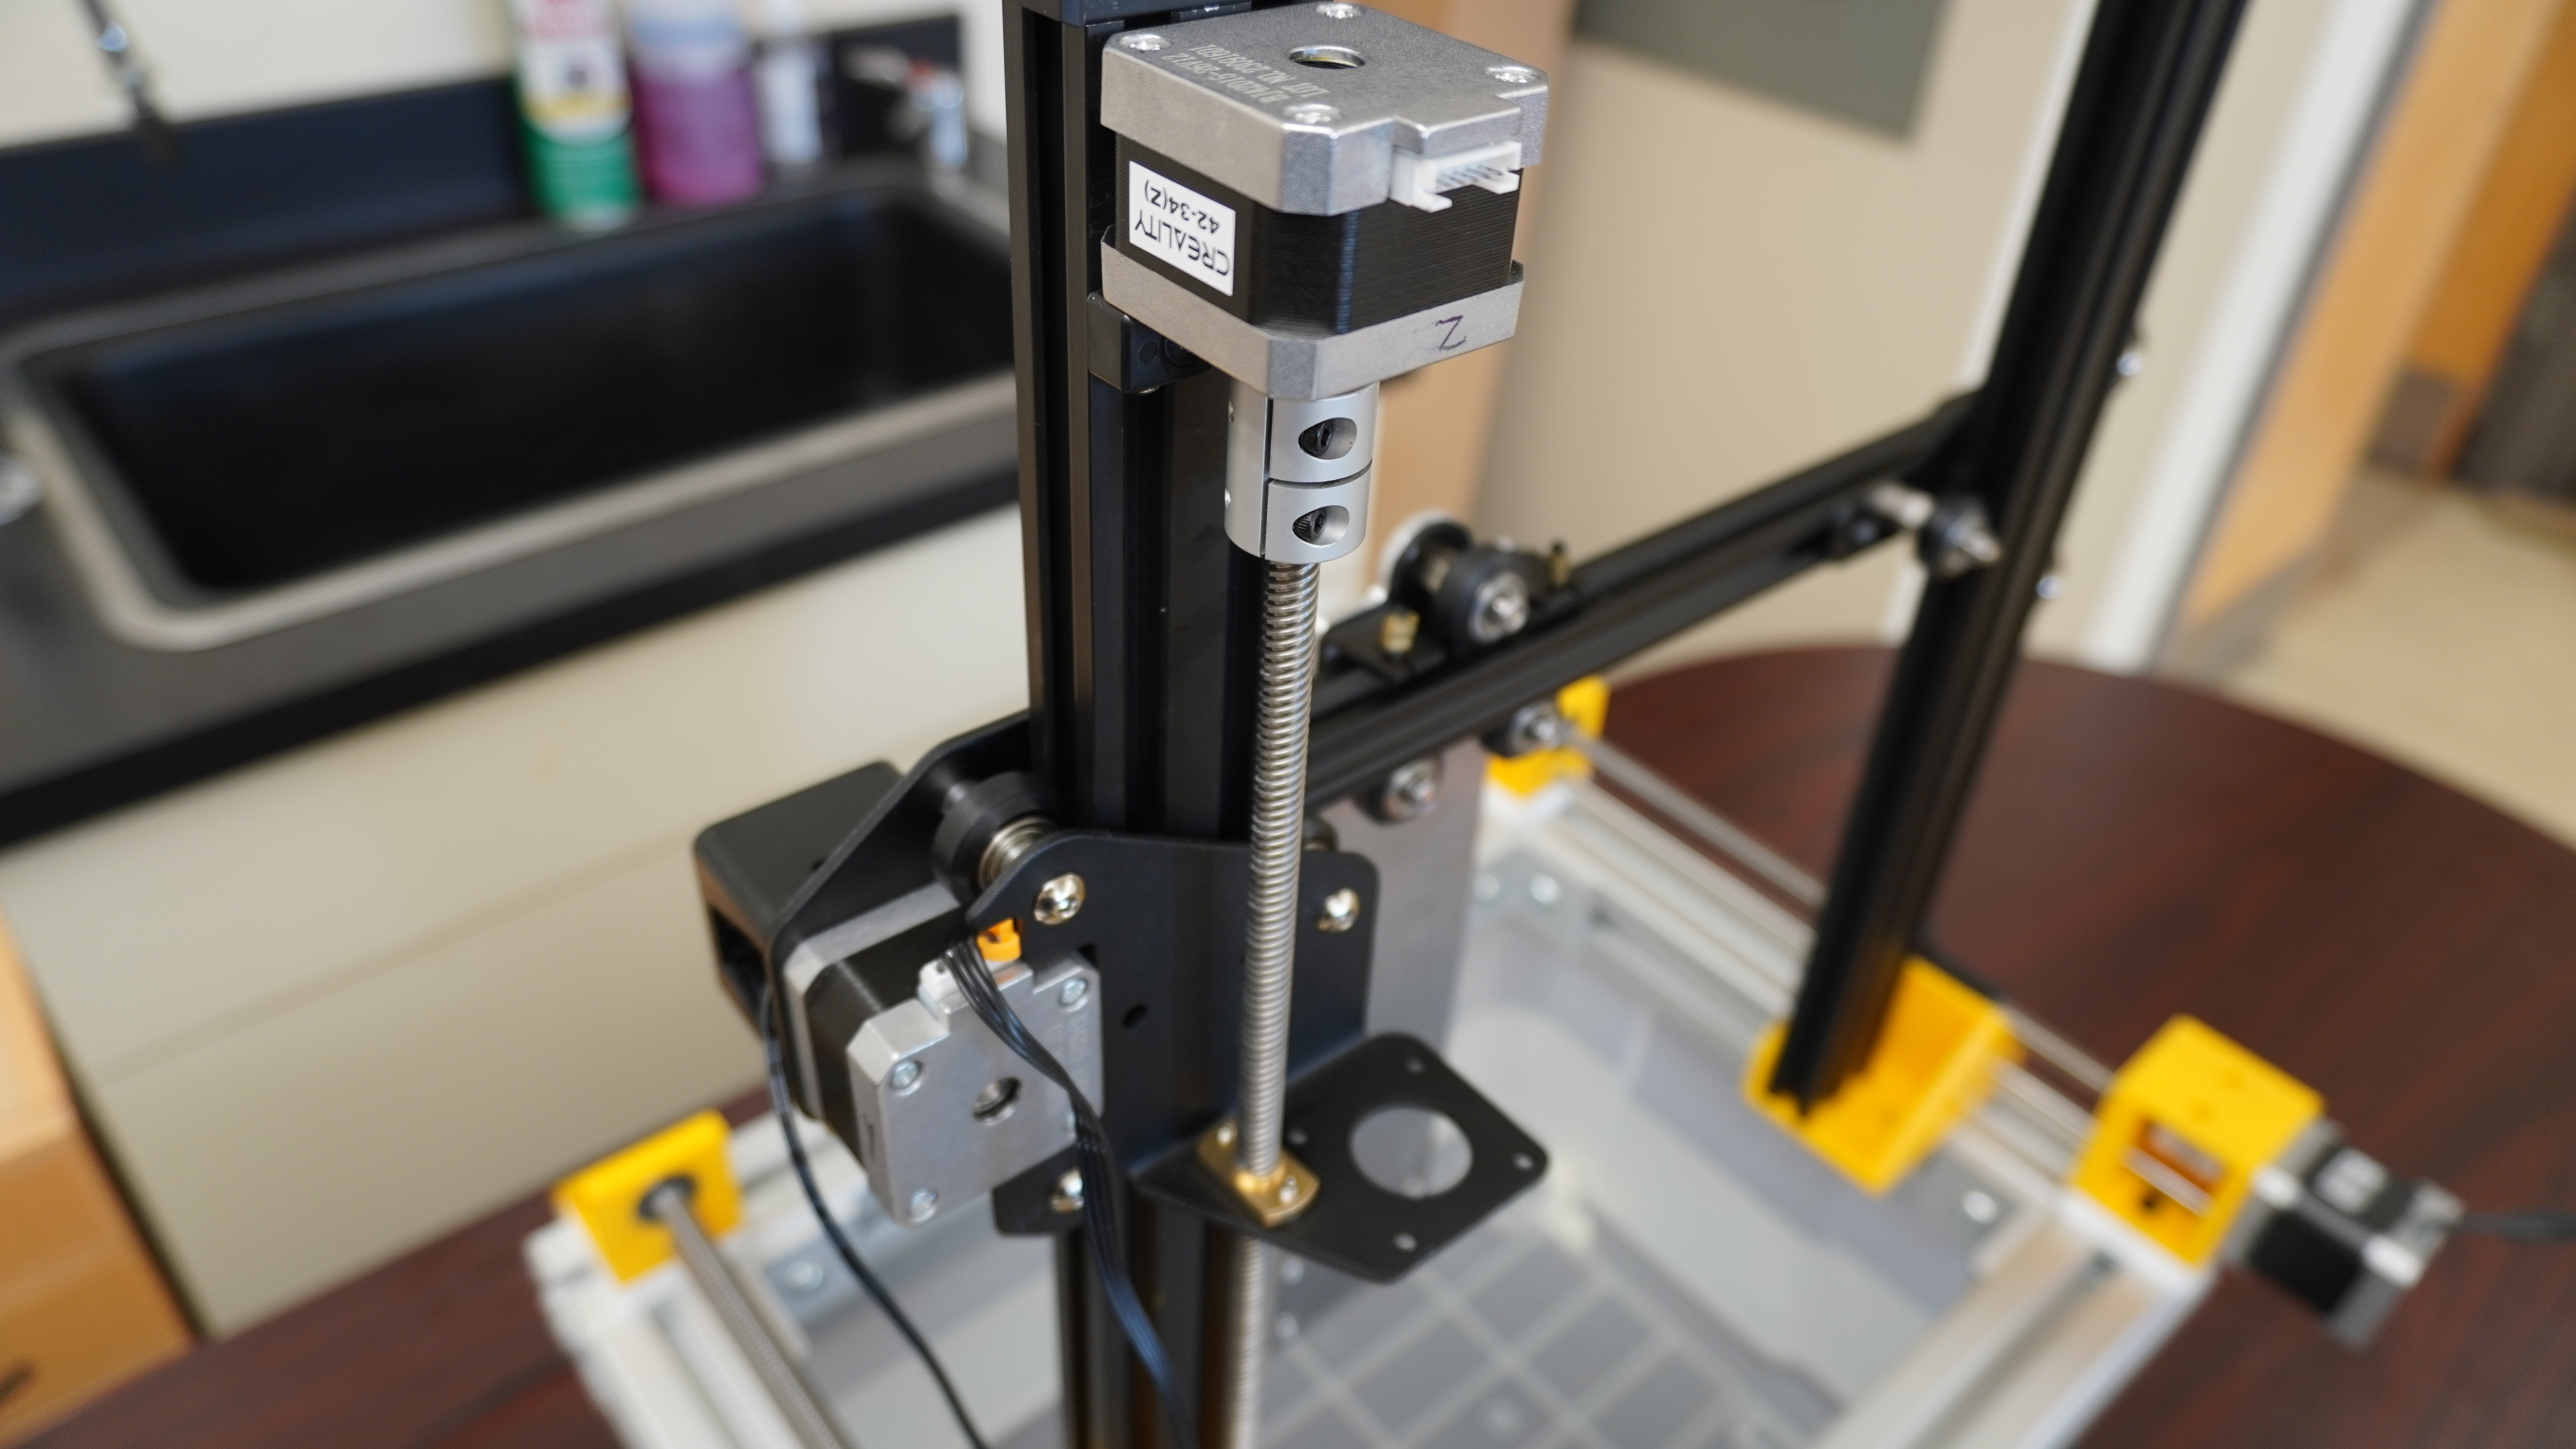
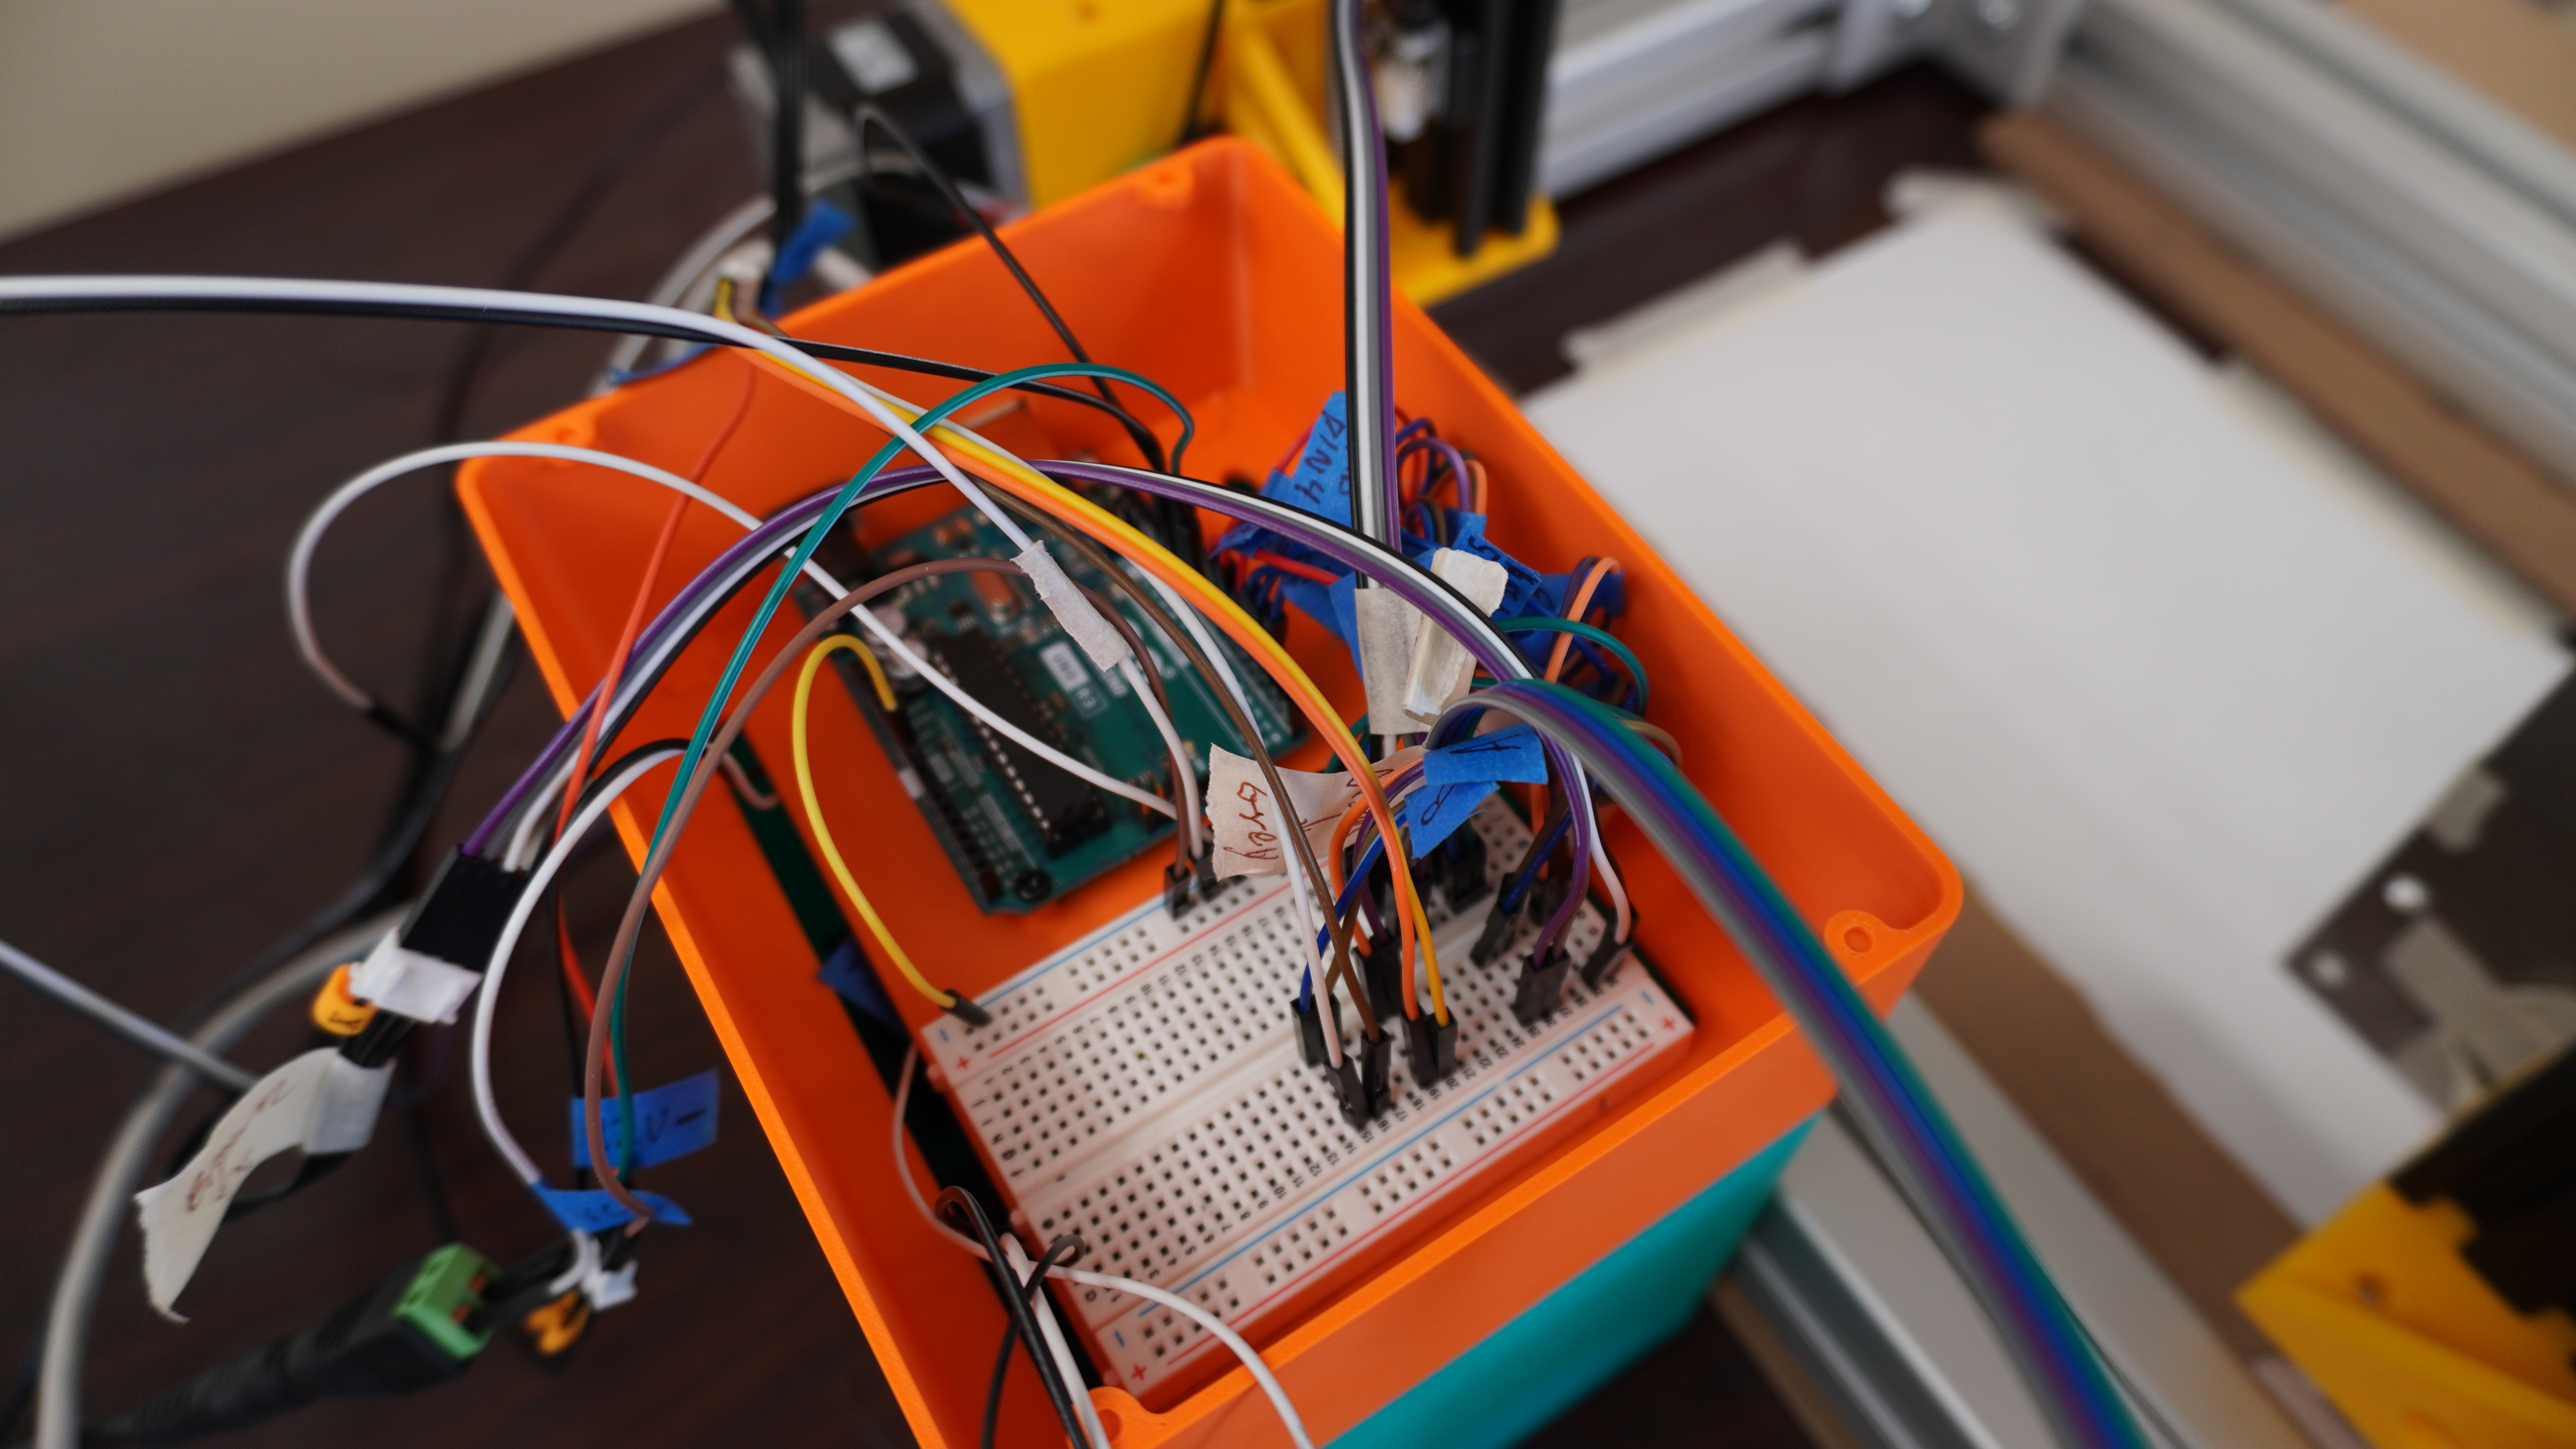
Utilized lead screws and timing belts driven by stepper motors. Controlled via Arduino Uno running custom GRBL firmware and micro-stepping drivers to execute automated G-code grid-scanning paths.
Acoustic Imaging Mechanism
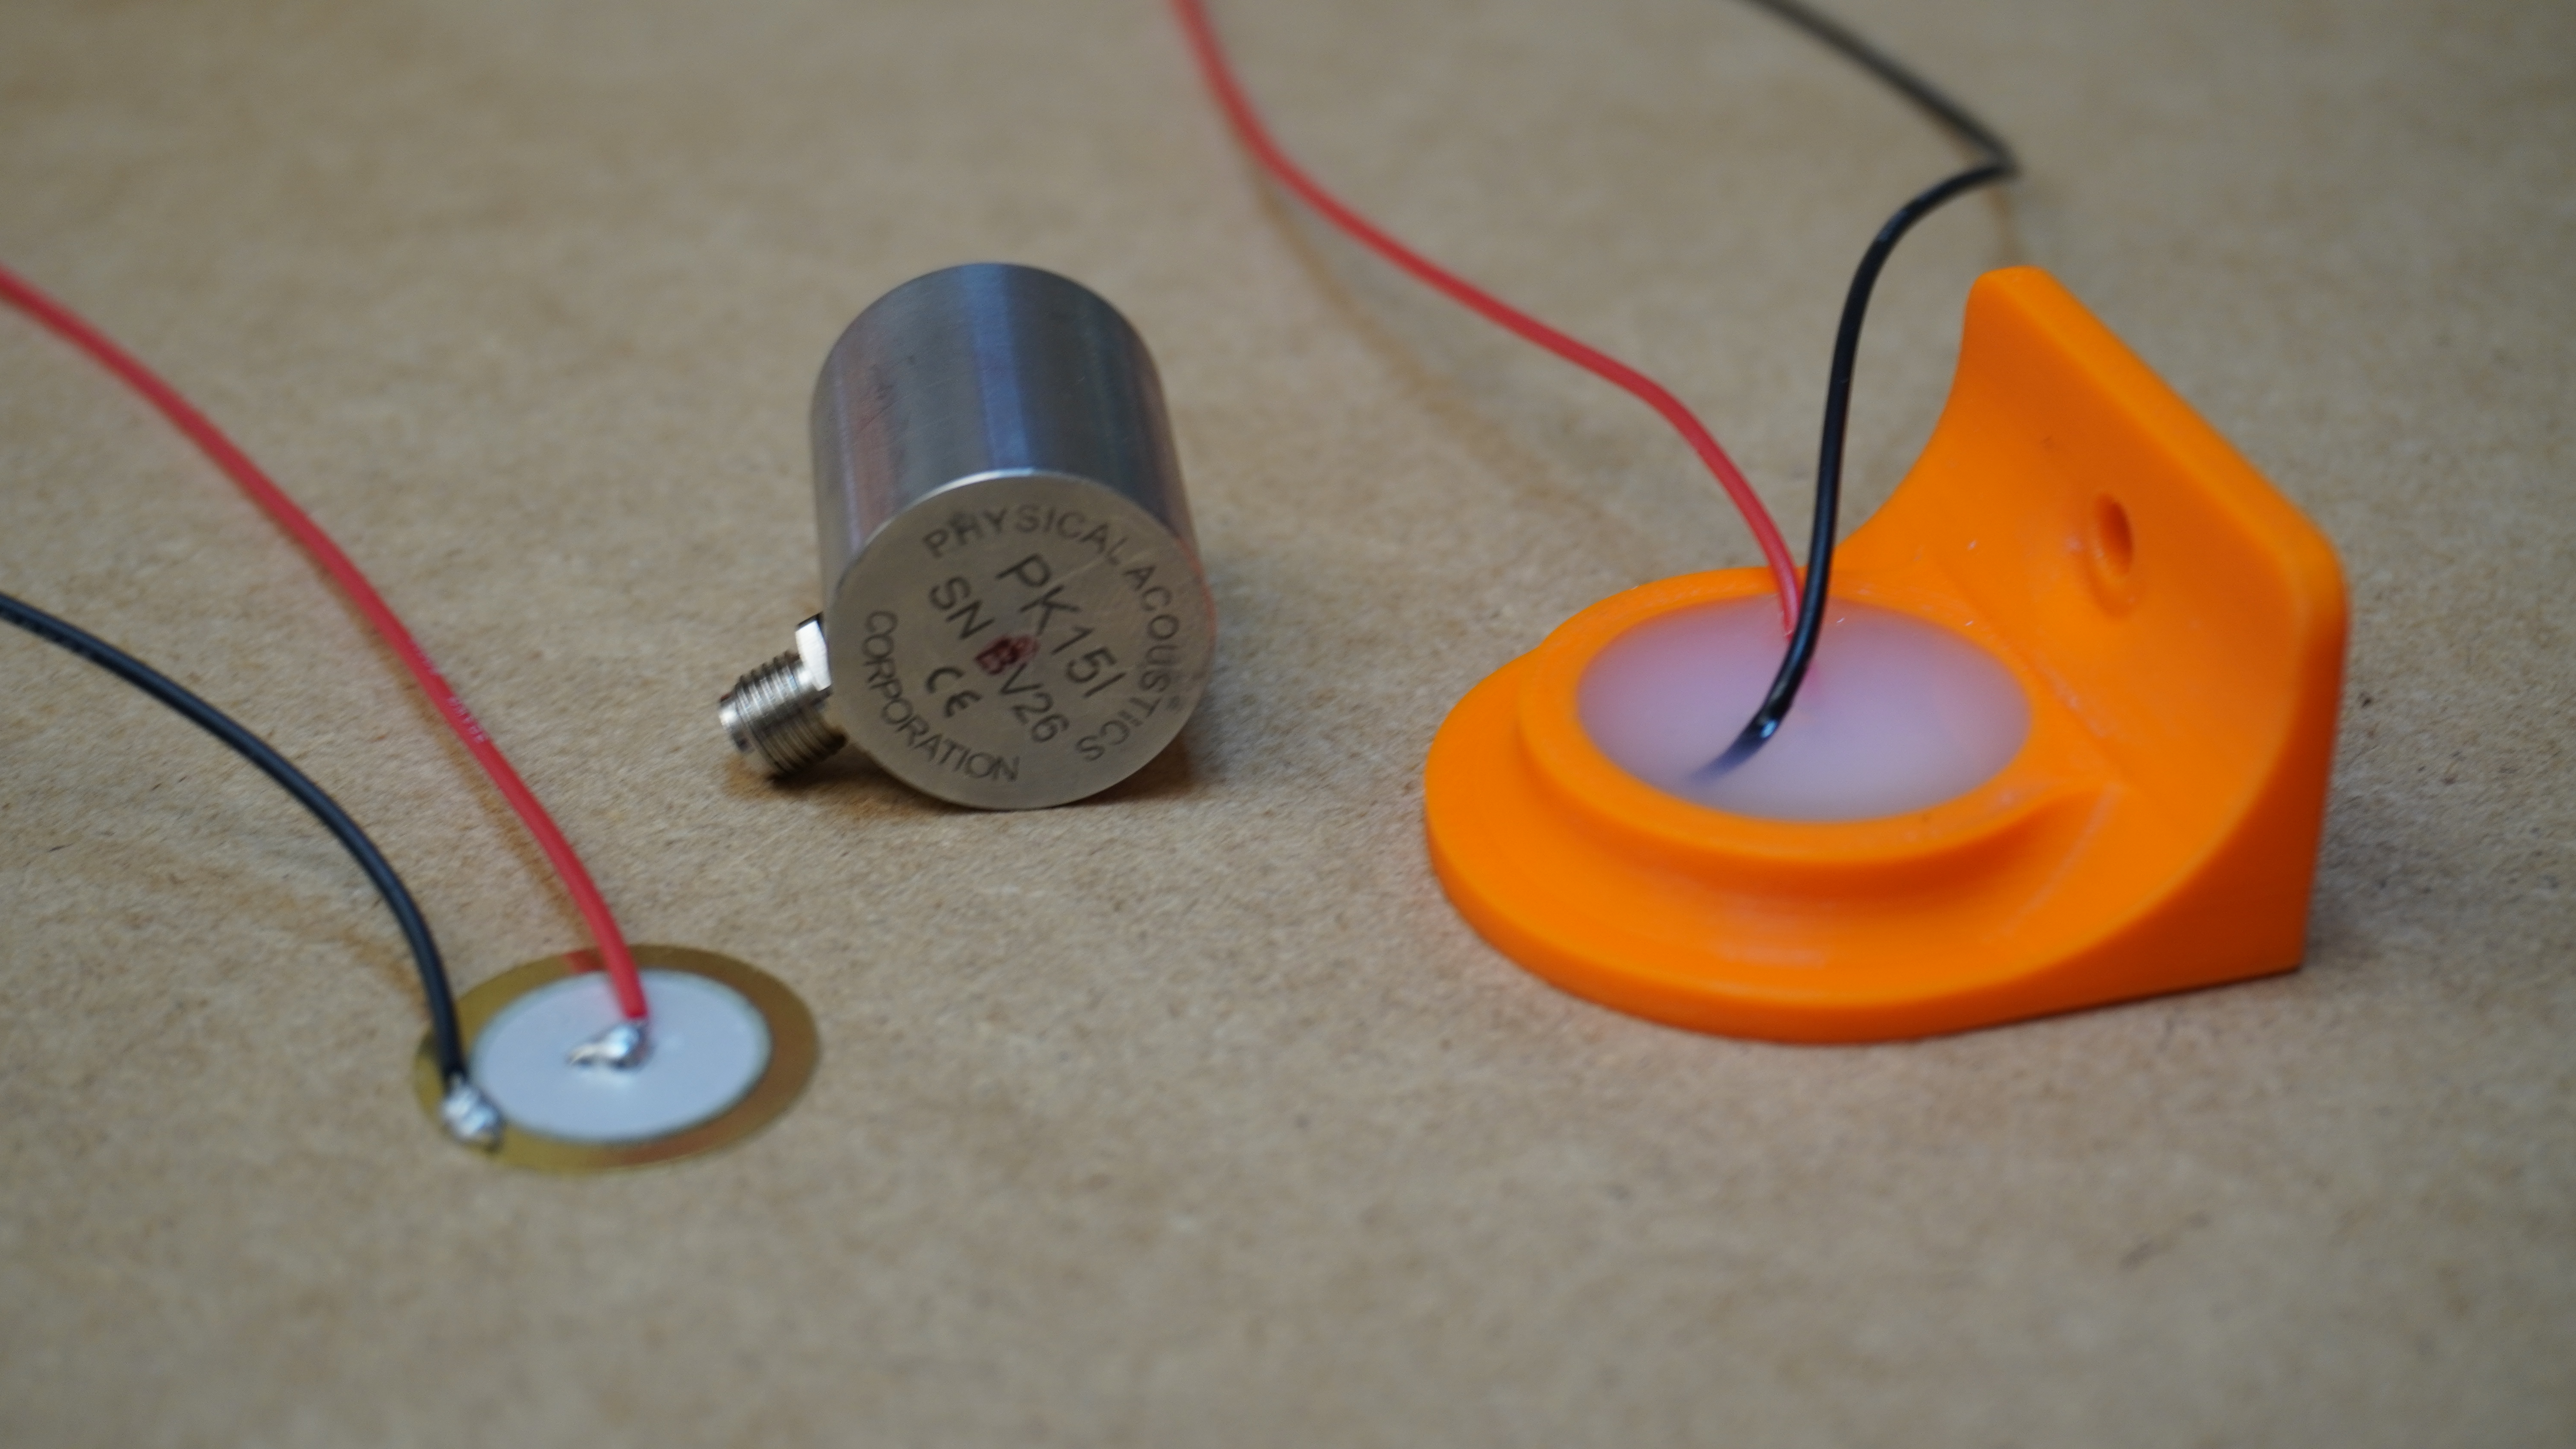
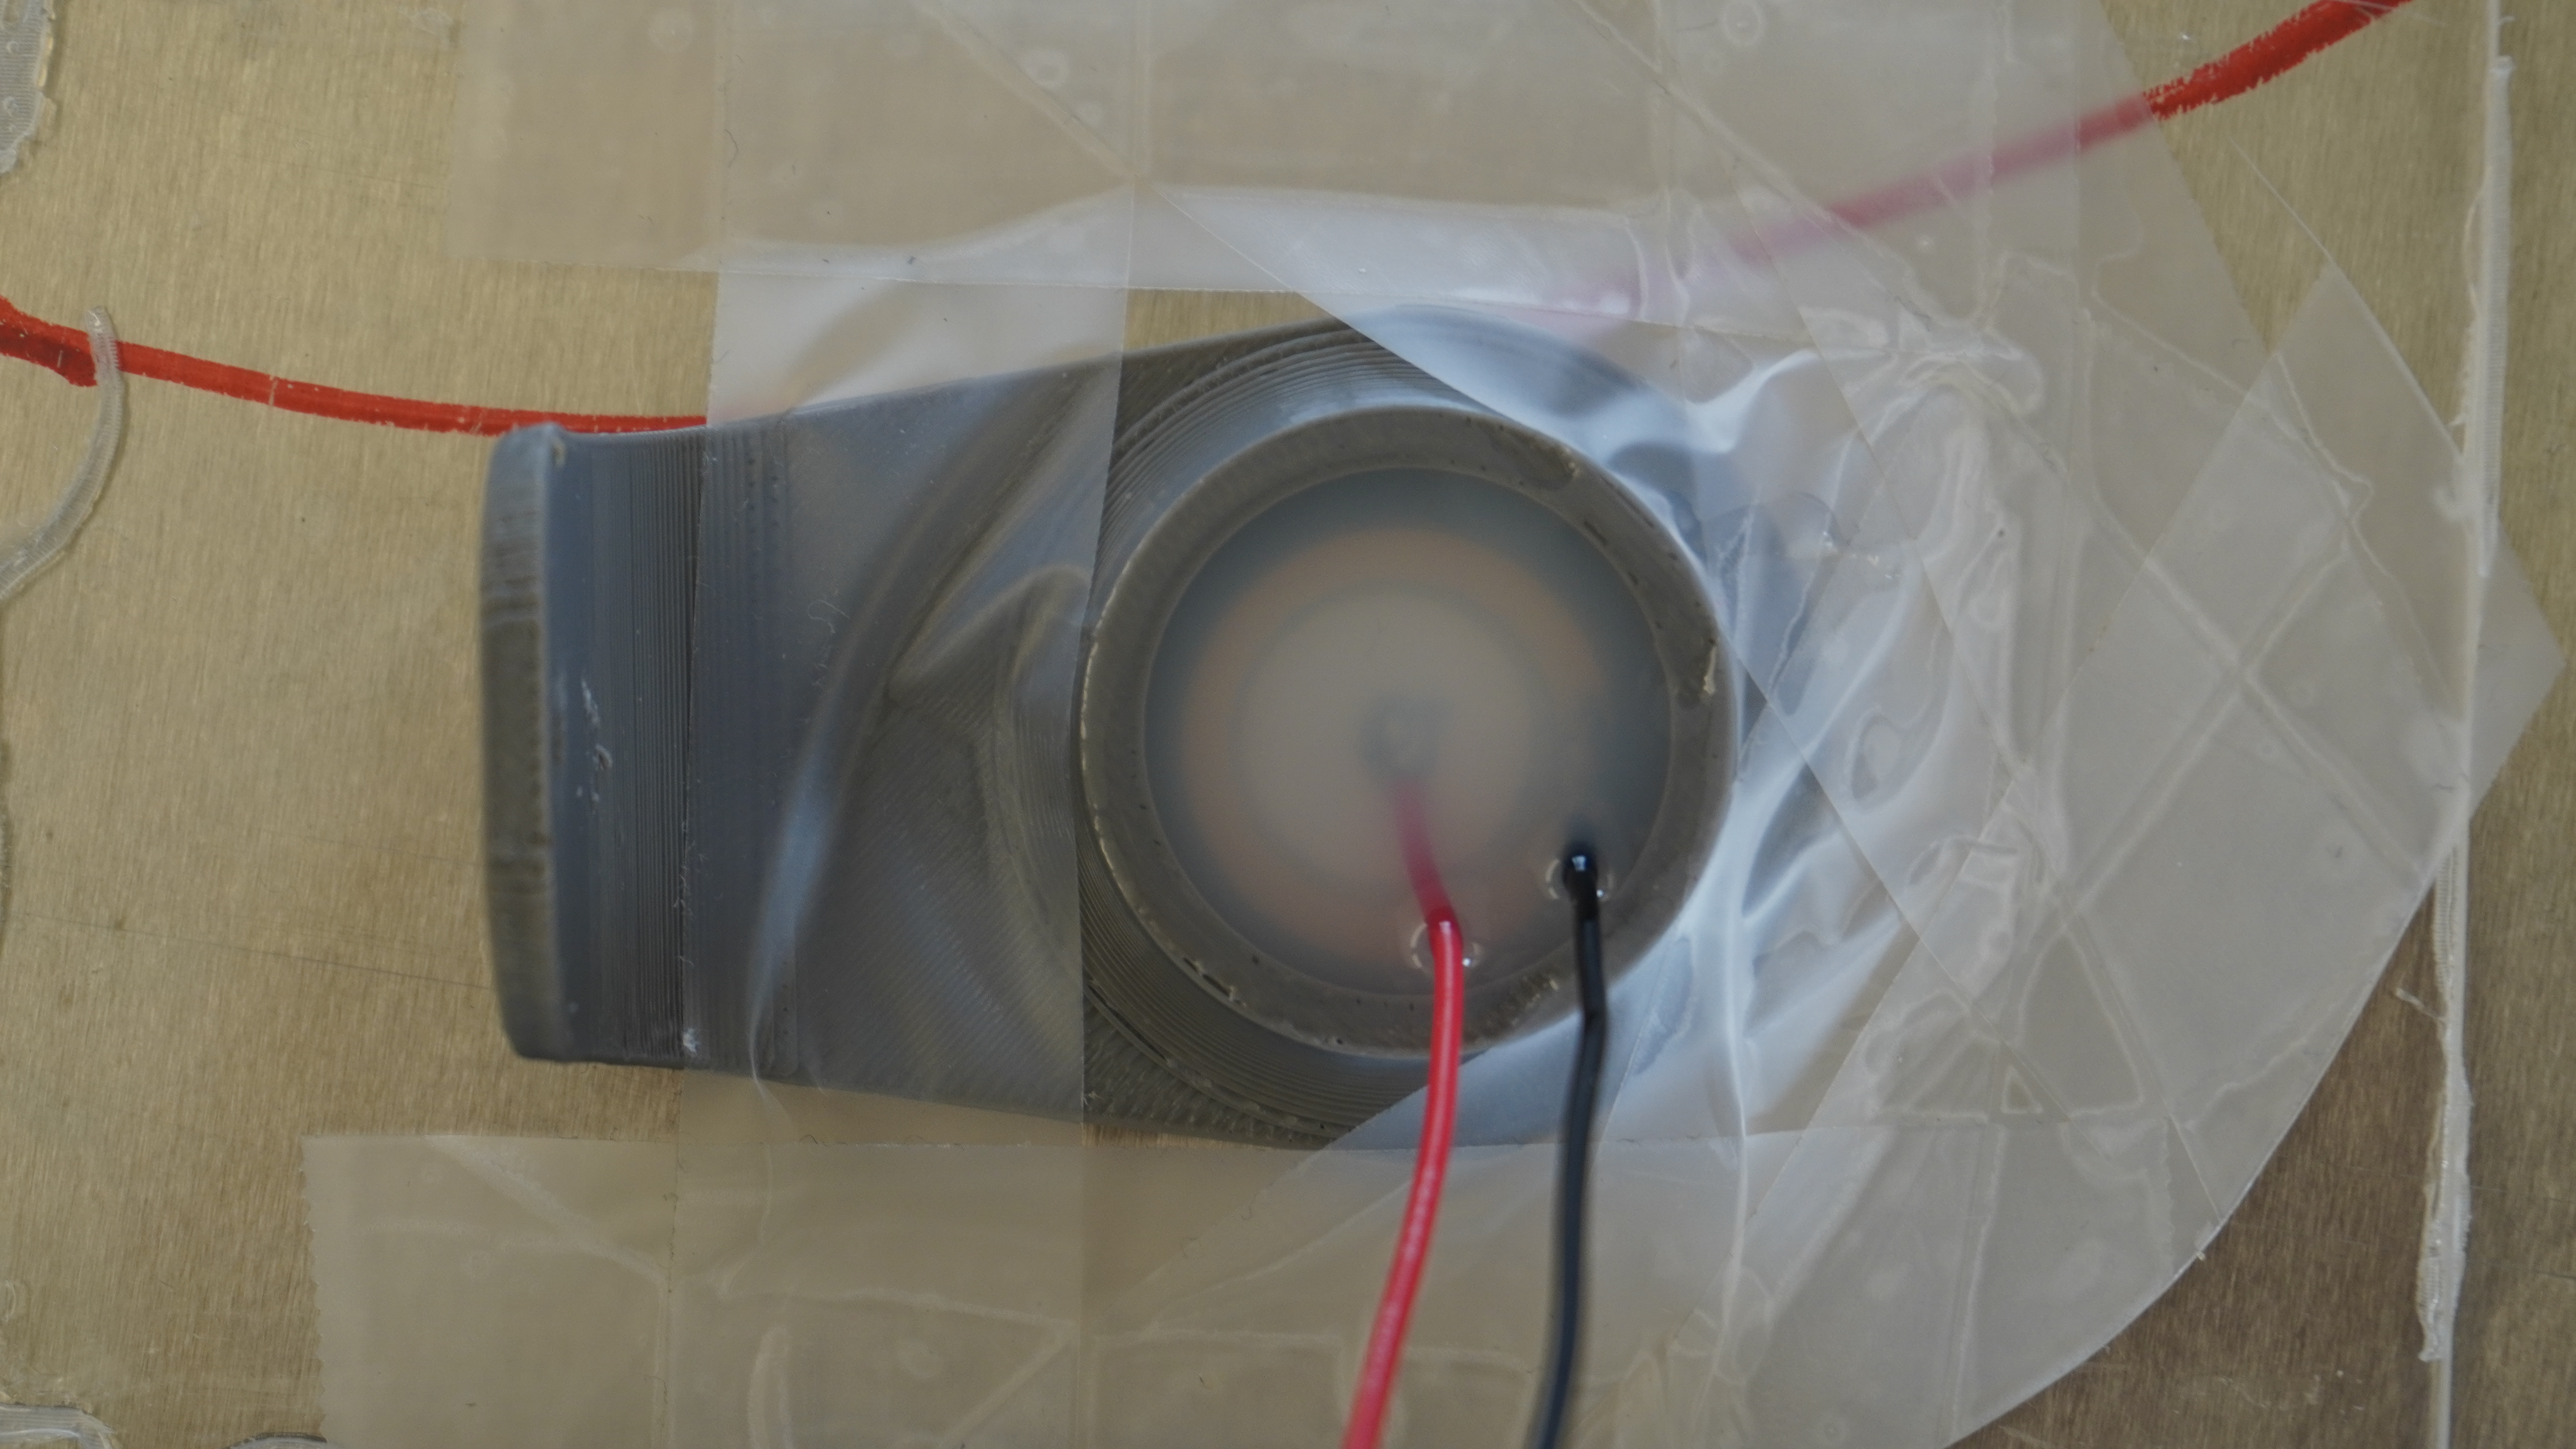
Features a dynamic sensing array with a piezoelectric disk active emitter sending acoustic pulses through water coupling, while high-sensitivity AE transducers capture returning waveforms.
- FEA Validation: Von Mises stress, static displacement, and modal frequency verified
- Controller: Arduino Uno + GRBL firmware with micro-stepping motor drivers
- Acoustics: Piezoelectric emitter disk + high-sensitivity AE receiver array
- Architecture: Portable, modular open-frame architecture for on-site research scaling